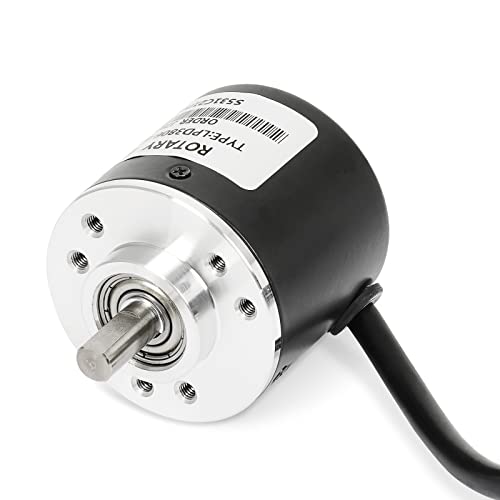
For Arduino builders, automation projects, robotics enthusiasts, and DIY control systems, getting accurate rotational feedback is often more important than adding another complicated component. The Incremental Optical Rotary Encoder for Arduino is designed to provide practical rotational position and direction feedback through a 360P/R quadrature output. With a wide DC 5-24V power range and a 6mm shaft, this sensor can fit into a variety of experimental and semi-professional control applications. If you’re searching for an Automatic professional streaming encoder Kit, it’s worth understanding that this product is a rotary encoder rather than a video or streaming encoder. Its value is in detecting mechanical rotation and translating that movement into electrical pulse signals that a controller can interpret.
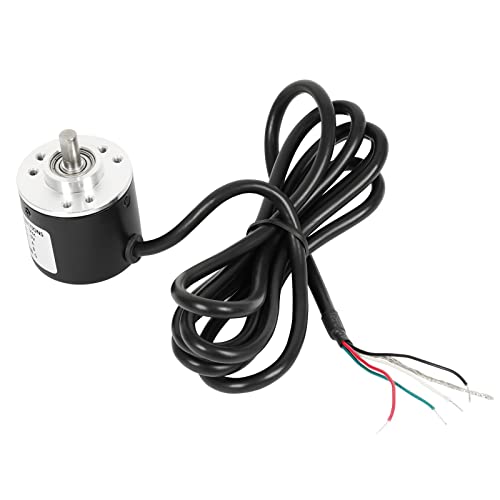
The basic idea is straightforward: as the shaft rotates, the optical sensing system generates pulses, while the quadrature signal provides information that can be used to determine both movement and direction. That makes this type of encoder useful in applications where a microcontroller needs to understand how far something has turned, how quickly it is moving, or which direction it is traveling.
What Is an Incremental Optical Rotary Encoder?
An incremental optical rotary encoder is an electromechanical feedback device that converts shaft rotation into digital signals. Unlike a simple switch that only tells a controller whether something is pressed or released, an incremental encoder can provide a stream of pulses corresponding to rotational movement.
The quadrature design is especially useful because it typically provides two output channels with a phase relationship between them. A compatible Arduino or other controller can analyze those channels to determine rotational direction while counting pulses to estimate movement. This makes the encoder suitable for projects involving motors, knobs, wheels, positioning mechanisms, automated machinery, and motion-control experiments.
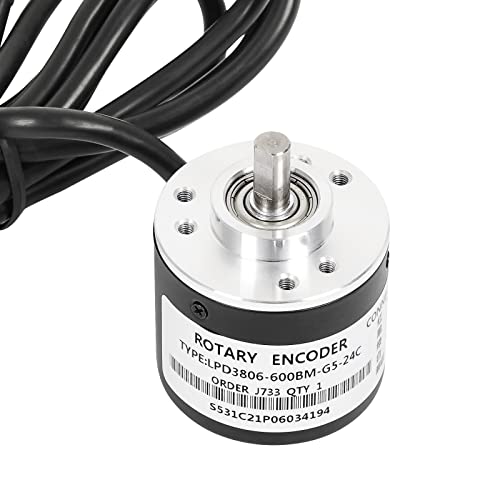
The advertised 360P/R specification gives builders a relatively fine level of rotational feedback compared with basic low-resolution encoder solutions. The 6mm shaft also gives it a familiar mechanical interface for compatible couplings, knobs, wheels, and other rotating components.
Key Features
360P/R Incremental Resolution
The 360P/R specification is one of the most important characteristics of this encoder. A higher pulse count can provide more detailed rotational feedback, which can be helpful when a project requires more precise monitoring of shaft movement. The actual usable resolution depends on how the controller interprets the encoder’s output and how the mechanical system is configured.
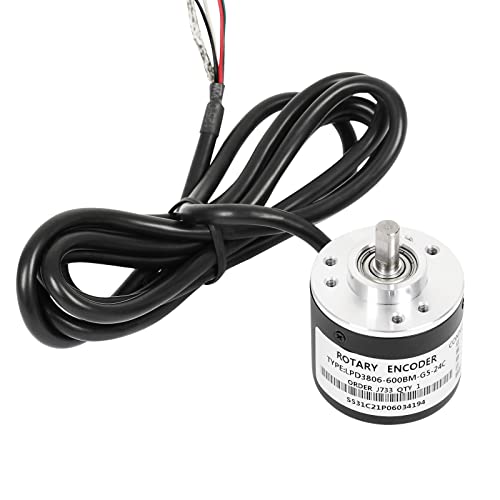
Quadrature Output
Quadrature signaling is a major advantage for motion-control projects because two related pulse signals can provide directional information. Instead of simply counting pulses, the microcontroller can compare the relationship between channels to identify clockwise and counterclockwise rotation.
For Arduino applications, this can make the encoder considerably more useful than a single-channel pulse sensor. It can be incorporated into projects where direction changes frequently, such as motorized mechanisms, rotary controls, robotic joints, or automated positioning systems.
Wide 5-24V DC Power Range
The stated DC 5-24V operating range gives the encoder flexibility when integrating it into different electrical systems. A 5V environment can be convenient for many Arduino-oriented projects, while the broader voltage range can make the device easier to integrate into certain industrial or automation setups.
Always verify the actual electrical specifications, wiring, output requirements, and controller compatibility before connecting the encoder. A wide supply range does not automatically mean that every output signal is directly compatible with every microcontroller input.
6mm Shaft
The 6mm shaft is another practical feature for mechanical integration. A standard-sized shaft can simplify the process of connecting the encoder to a rotating mechanism, coupling, wheel, or custom assembly. Proper alignment is still important because excessive side loading or mechanical misalignment can affect the longevity and reliability of a rotary encoder.
Optical Sensing Technology
Optical encoding uses light-based detection to identify changes associated with shaft rotation. For applications requiring repeatable pulse generation, this approach can be more sophisticated than simple mechanical contact-based sensing.
That makes the encoder attractive for builders who want digital rotational feedback without relying on a conventional mechanical potentiometer. It can serve as a useful component in systems where the controller needs continuous motion information rather than simply an approximate knob position.
Pros & Cons
| Pros | Cons |
|---|---|
| 360P/R resolution provides detailed rotational feedback | Requires suitable controller programming and signal handling |
| Quadrature output can provide rotational direction information | Mechanical installation and shaft alignment require care |
| Wide DC 5-24V power range offers integration flexibility | Output compatibility should be checked before connecting to a microcontroller |
| 6mm shaft is convenient for many mechanical assemblies | Not a video or broadcast streaming encoder despite keyword terminology |
| Useful for Arduino, robotics, automation, and motion projects | Performance depends on controller software, wiring, and mechanical setup |
| Optical sensing is well suited to pulse-based motion feedback | Additional hardware may be required for a complete automation system |
Performance in Arduino Projects
In an Arduino-based project, the most important question is how reliably the encoder communicates rotational movement to the microcontroller. With quadrature output, the Arduino can monitor the encoder channels and determine changes in direction while counting transitions. This allows developers to build systems that respond to physical rotation rather than relying on fixed timing assumptions.
For example, an encoder can be attached to a rotating control mechanism. When the shaft turns clockwise, the software can increase a variable; when it turns in the opposite direction, the software can decrease that variable. The resulting value can then control another function such as motor speed, menu selection, brightness, positioning, or automated movement.
The 360P/R specification can also be useful when a project needs finer rotational feedback. However, resolution should not be confused with absolute positioning accuracy. An incremental encoder generally reports changes in rotation rather than automatically knowing its absolute mechanical position after power-up. Depending on the application, the system may therefore require a homing routine, reference mark, limit switch, or other position reference.
Why Quadrature Matters
One of the biggest benefits of quadrature encoding is directional detection. With two output channels offset from one another, software can determine which signal changes first and use that sequence to infer direction.
This matters in real-world automation. Imagine a motorized adjustment mechanism that moves forward and backward. A single pulse channel might tell the controller that movement occurred, but quadrature feedback can provide additional information about whether the shaft moved forward or backward.
For an Arduino enthusiast, this opens the door to more advanced projects. You can use encoder feedback with motors, gears, wheels, robotic mechanisms, rotary interfaces, and other moving assemblies.

Installation and Integration Considerations
Mechanical installation deserves as much attention as the electrical connection. The encoder shaft should be properly aligned with the rotating component. A coupling that is too rigid or poorly aligned can introduce unwanted forces into the shaft and bearing system.
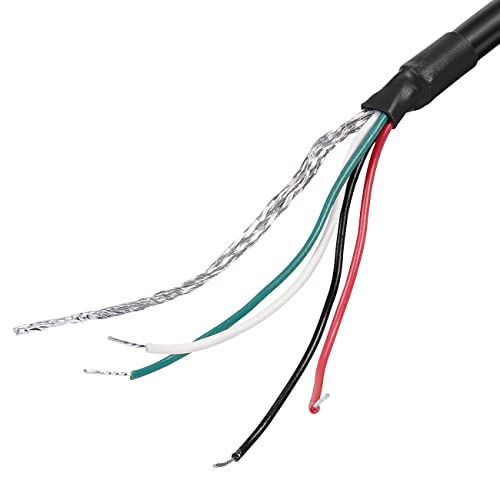
Electrical wiring should also be planned carefully. Confirm the power connections and identify the output channels before connecting the device to an Arduino. If the encoder’s output voltage or electrical interface does not match the controller’s expected input levels, an appropriate interface circuit may be necessary.
Software is equally important. Quadrature encoders can generate a substantial number of signal transitions depending on rotational speed and how the pulses are counted. The Arduino code therefore needs to be designed to handle the expected pulse frequency without missing important transitions.
Performance for Automation
For automation experiments, this encoder can provide an inexpensive way to introduce rotational feedback into a system. Instead of telling a motor to operate for a predetermined amount of time and assuming that it reached the desired position, encoder feedback can allow a controller to monitor actual rotational movement.
This principle is common in motion-control systems. Feedback can be used to measure movement, detect direction changes, monitor a rotating component, or provide input to a control algorithm.
Of course, the encoder alone does not turn a project into an industrial automation system. The final performance depends on the motor, mechanical transmission, controller, software, power supply, mounting arrangement, and operating environment. Nevertheless, it can be a useful building block for creating more intelligent motion systems.
Is It Suitable for Professional Projects?
This depends heavily on the application. For prototyping, educational projects, hobby automation, robotics, and custom machinery, an incremental optical encoder can be a practical feedback component. For safety-critical or highly regulated industrial equipment, engineers should evaluate the complete encoder specification, environmental ratings, electrical interface, tolerance, lifecycle, documentation, and required certifications rather than selecting a component based only on resolution or voltage range.
The product is particularly interesting for makers who want to move beyond simple switches and potentiometers. Its quadrature output provides a pathway toward more sophisticated feedback-based control.
Practical Arduino Project Ideas
There are many ways to experiment with an encoder like this. A rotary control project could use the encoder to navigate a digital menu. A motor-control project could use the pulses as feedback for movement. A robotics project could monitor wheel rotation. A camera-positioning mechanism could use encoder feedback to track adjustments.
It could also be incorporated into custom test equipment where the controller needs to record rotational movement. Once the encoder signals are being read correctly, the software possibilities become quite broad.
If you are building a larger DIY automation setup that includes mechanical, electrical, and home equipment components, you may also find this Related Guide useful as an example of another equipment-focused project category.
What to Check Before Buying
Before purchasing an incremental encoder, check several specifications beyond the advertised pulse count. Confirm the supply voltage, output type, shaft dimensions, mounting dimensions, cable or connector arrangement, maximum rotational speed, environmental specifications, and signal compatibility.
It is also worth considering how the encoder will physically connect to your mechanism. The correct shaft diameter alone does not guarantee compatibility. You may need a flexible coupling, mounting bracket, adapter, or custom hardware.
Frequently Asked Questions
What does 360P/R mean?
360P/R generally refers to 360 pulses per revolution. The exact interpretation of the encoder’s resolution can depend on the manufacturer’s specification and how the controller counts the quadrature transitions.
Can this encoder work with Arduino?
It is intended for applications such as Arduino-based projects, but you should verify the encoder’s output electrical characteristics and wiring against the specific Arduino board you plan to use.
What is quadrature output?
Quadrature output normally uses two pulse channels with a phase difference. By examining the sequence of those signals, a controller can determine both rotational movement and direction.
Does an incremental encoder know its absolute position?
No. An incremental encoder normally reports changes in rotation. After power is removed or the system is restarted, the controller may need a reference position or homing procedure to establish absolute mechanical position.
What voltage can this encoder use?
The product description specifies a DC 5-24V power supply range. Always verify the exact wiring and electrical specifications before installation.
Is this a professional streaming encoder?
No. Despite the keyword phrase Automatic professional streaming encoder Kit, this product is a rotary motion encoder. It detects shaft rotation and outputs electrical pulse signals; it is not intended to encode or transmit audio/video streams.
What can I build with it?
Potential applications include Arduino controllers, robotics, motor feedback systems, rotary interfaces, automated positioning mechanisms, wheel rotation monitoring, and custom motion-control projects.
Does higher resolution always mean better performance?
Not necessarily. Higher pulse resolution can provide more detailed feedback, but the complete system must be able to process the generated signals. Mechanical accuracy, controller performance, software design, wiring, and installation quality all influence the final result.
Final Thoughts
The Incremental Optical Rotary Encoder for Arduino offers a practical combination of 360P/R rotational feedback, quadrature output, a 6mm shaft, and a stated DC 5-24V supply range. Those specifications make it an interesting component for makers, robotics developers, Arduino users, and automation enthusiasts who need digital feedback from a rotating shaft.
Its greatest strength is flexibility. Rather than functioning as a simple on/off sensor, it gives a controller information that can be used to track rotational movement and direction. That makes it suitable as a building block for more advanced motion-control projects.
At the same time, successful implementation depends on correct electrical integration, appropriate programming, careful mechanical alignment, and a realistic understanding of incremental encoder operation. If those factors are handled correctly, this type of optical quadrature encoder can add a useful layer of feedback to a wide range of DIY and automation systems.